
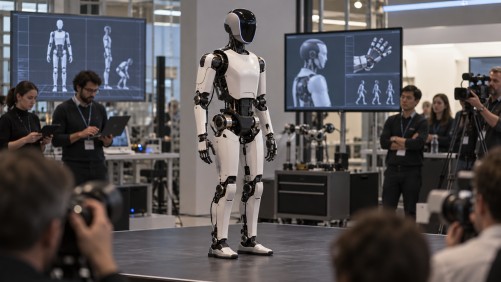
OpenAI is venturing into the realm of robotics with plans to develop a humanoid robot, aiming to showcase its technology by 2027. This initiative underscores OpenAI’s ambition to extend artificial intelligence from digital platforms into the physical world, as noted by CEO Sam Altman. The project emphasizes the development of AI systems that can reliably understand and interpret their surroundings, execute instructions, and control physical machines.
Altman has pointed out that creating a humanlike robot design could be advantageous, as it would allow the robots to operate effectively in environments designed for human use. However, the company has not yet disclosed details about the robot’s final design, technical specifications, or potential demonstration capabilities. The development of such a robot will require significant advancements in areas such as perception, movement, decision-making, and the integration of mechanical components to ensure safe task execution.
To realize this vision, OpenAI is actively recruiting specialists in various fields, including robotics software and hardware, control systems, motion technologies, motor design, machine learning, and manufacturing. These roles are crucial for building the necessary technological infrastructure for practical robotic applications.
OpenAI’s endeavor faces competition from other technology companies such as Tesla, which is working on its Optimus humanoid robot, and Chinese automaker XPENG, known for its IRON robot. These projects highlight a growing interest in merging AI with machines capable of performing physical tasks, reflecting a broader industry trend.
Beyond humanoid robots, OpenAI’s long-term goals include developing general-purpose robots that could assist skilled workers in infrastructure construction and eventually support a broader range of everyday activities. The company is also exploring alternative robotic designs that may not necessarily follow a humanoid model, indicating a commitment to versatile and practical AI applications in the physical world.